ETH Zurich · EPFL

Léonard Court

Robot Learning, Reinforcement Learning & Computer Vision

M.Sc. student in Robotics, Systems and Control at ETH Zurich, following a B.Sc. in Mechanical Engineering at EPFL and a study-abroad year at the University of Illinois Urbana-Champaign.

I am focusing on robot learning and computer vision: teaching robots to act from data through imitation and reinforcement learning, and to perceive their environment, with rigorous evaluation on situations they have never seen.

Available from September 2027. Open to conversations before then.

Zurich, Switzerland

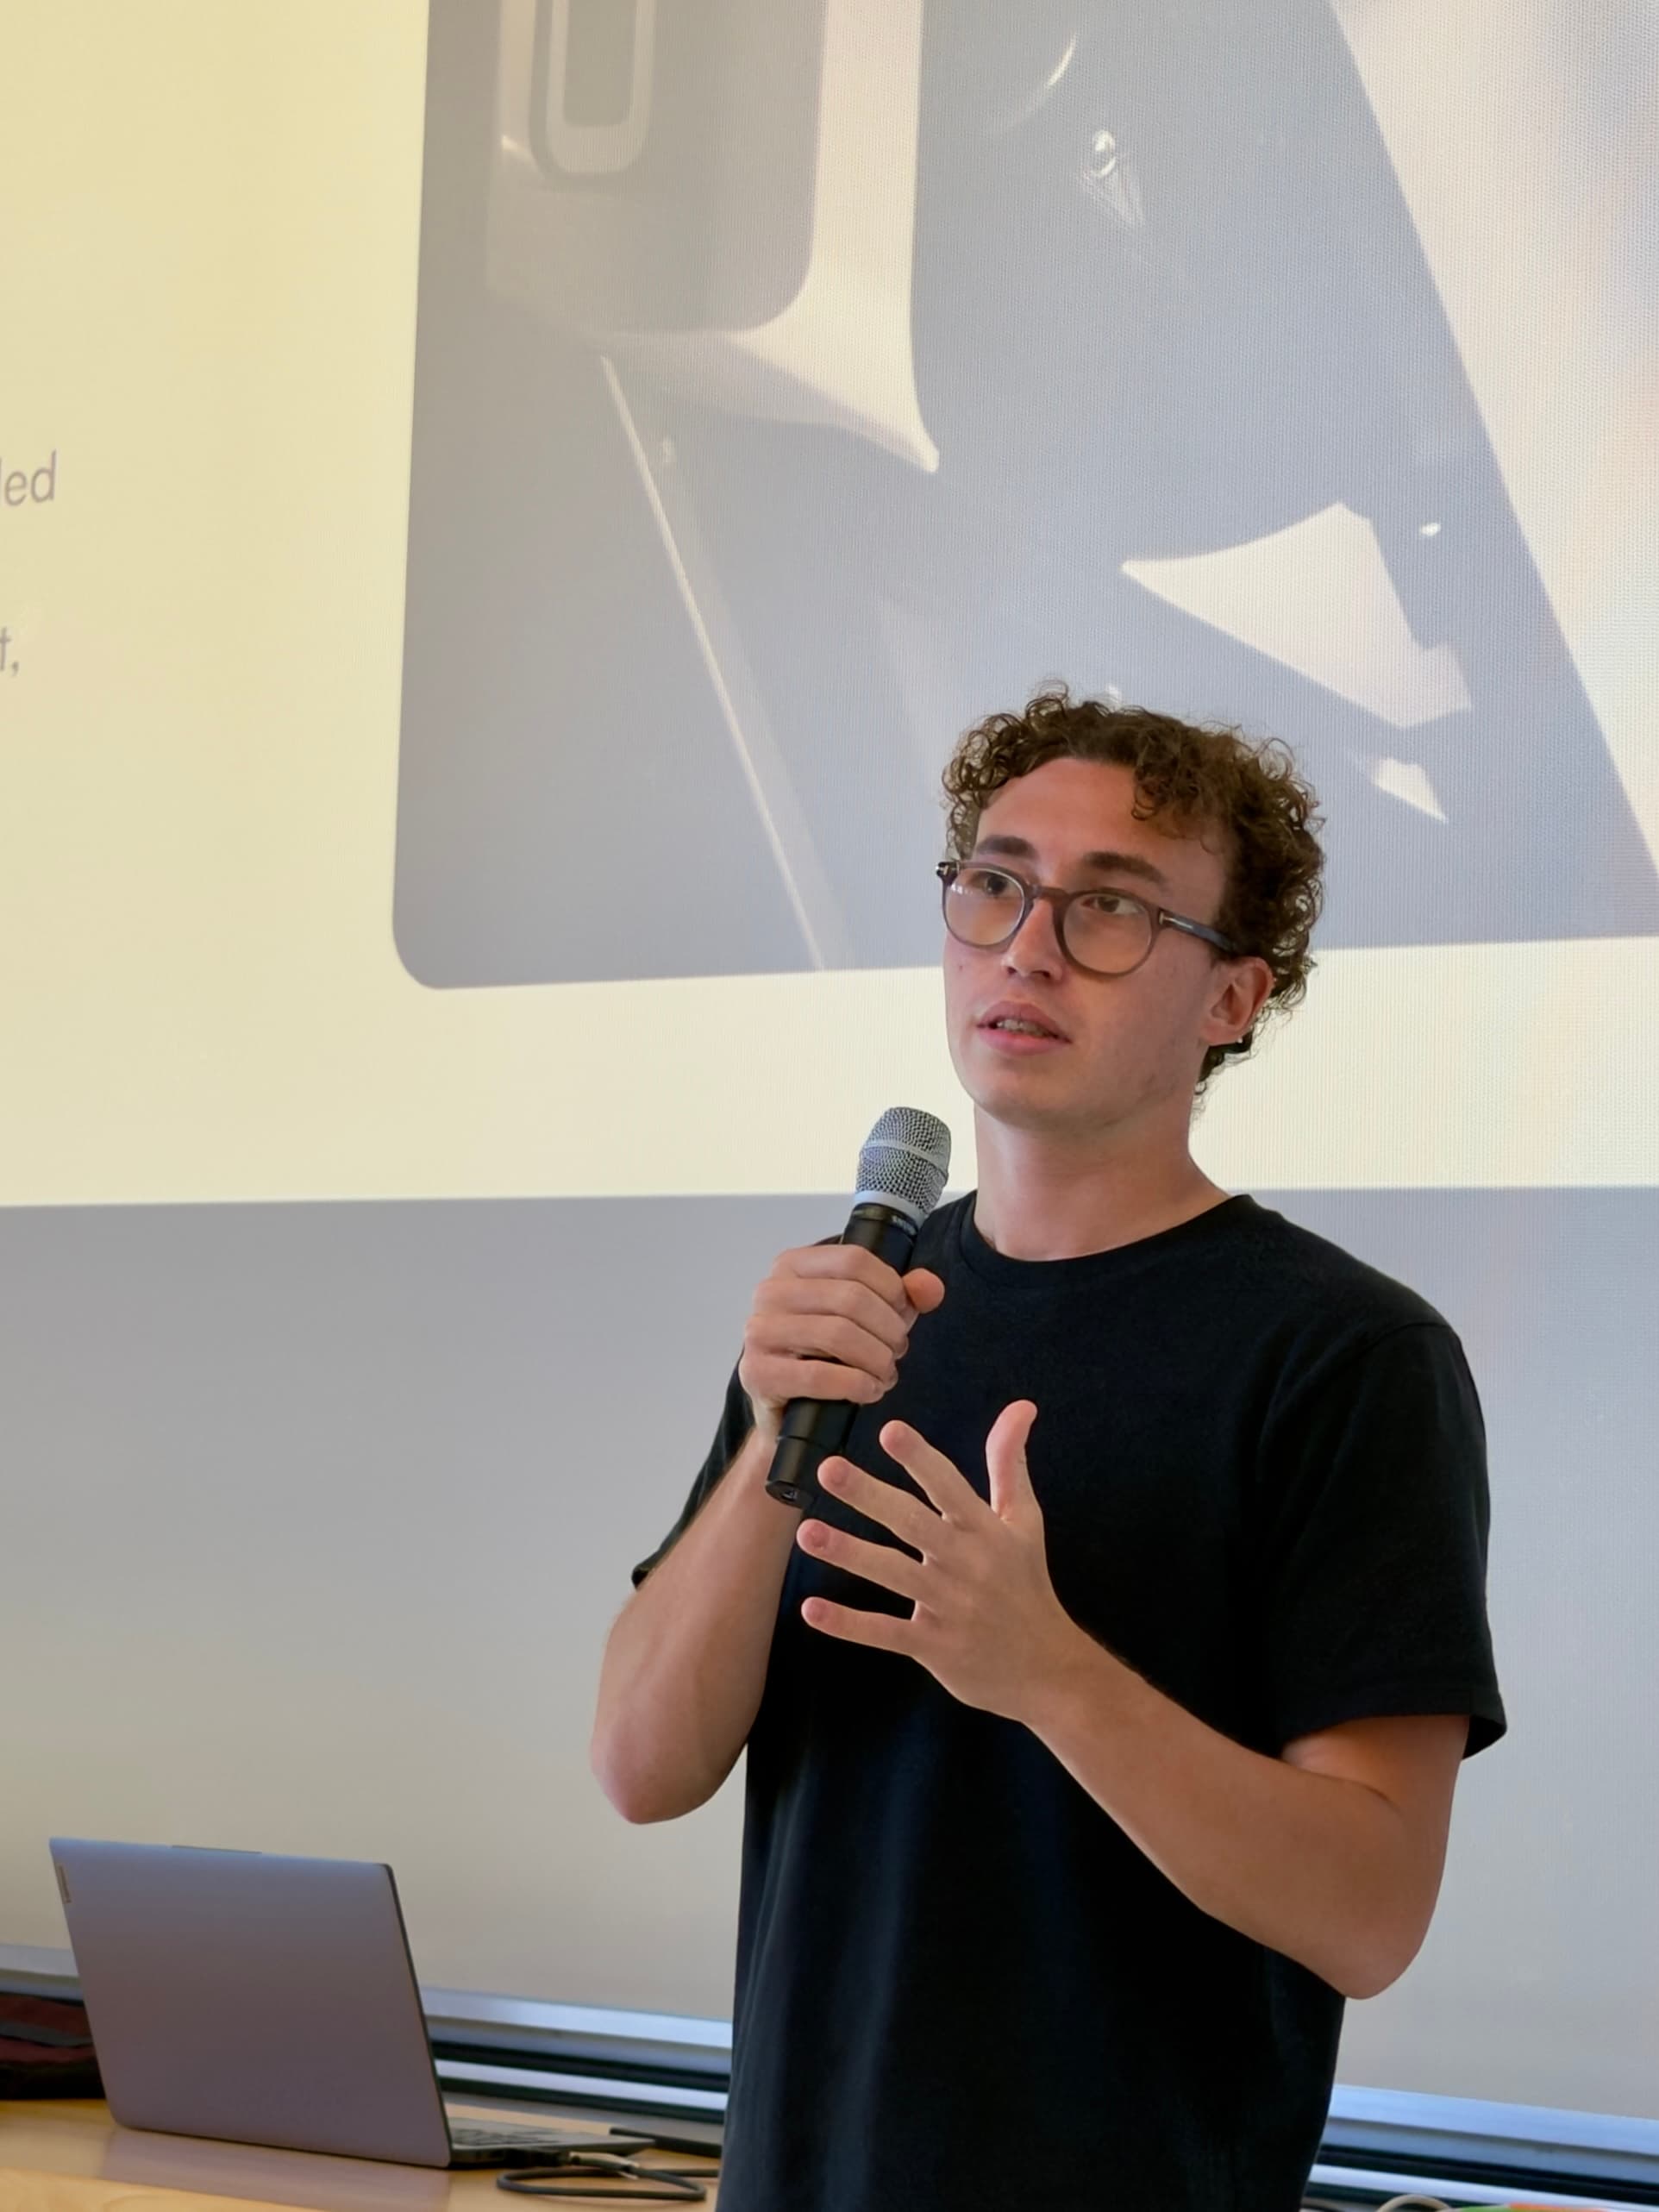
Léonard Court presenting

Areas of focus

The technical areas connecting my projects and studies.

I am building toward robot learning and computer vision, on top of a foundation in control and mechanical engineering: learned behavior is only useful if it stays reliable on hardware and on unseen situations.

01

Robot Learning & Reinforcement Learning

Imitation learning (behavior cloning, DAgger), reinforcement learning (PPO), policy architectures, and evaluation on unseen environments.

02

Computer Vision for Robotics

Visual perception for mobile robots: feature-based vision, camera geometry, and visual odometry, studied through Vision Algorithms for Mobile Robotics.

03

Control & Dynamics

Robot dynamics, model predictive control, and optimal control, used both on their own and as strong baselines and experts for learning-based methods.

Projects

Selected projects

Expert vs imitation vs reinforcement learning

01Robotics · Machine Learning · Reinforcement Learning

Learning-Based Robot Navigation

A simulated two-wheeled robot learns to reach a goal while avoiding obstacles. I compared a hand-written controller, imitation learning (BC + DAgger) and reinforcement learning (PPO) on 500 unseen test maps.

Role
Personal project (solo)
Date
2026
PyTorchStable-Baselines3ROS 2DockerGymnasium
View code on GitHub ↗

1 / 4 Project 1 of 4: Learning-Based Robot Navigation

Background

Education and experience

Two separate tracks: academic education, and professional, teaching, and leadership experience.

Education

ETH Zurich

Sep 2026 – Aug 2028 (expected)

M.Sc. Robotics, Systems and Control

Zurich, SwitzerlandCurrent graduate student

Current coursework (Fall 2026)
  • Probabilistic Artificial Intelligence
  • Vision Algorithms for Mobile Robotics (UZH)
  • Robot Dynamics
  • Model Predictive Control
  • Dynamic Programming and Optimal Control

University of Illinois Urbana-Champaign

Aug 2025 – May 2026

Study-abroad year, Mechanical Engineering (Grainger College of Engineering)

Urbana-Champaign, Illinois

Credited as the third year of the EPFL B.Sc.

Selected coursework
  • Applied Machine Learning
  • Control Systems
  • Intermediate Dynamics
  • Dynamics of Mechanical Systems
  • Intermediate Solid Mechanics
  • Finite Element Analysis
  • Technology Innovation & Strategy

École Polytechnique Fédérale de Lausanne (EPFL)

Sep 2023 – Jul 2026

B.Sc. Mechanical Engineering

Lausanne, Switzerland

Overall average 5.51 / 6.0

Activities & leadership
Ground Station Engineer, EPFL Rocket TeamTeaching Assistant (4 courses)First-Year Student Coach
Selected quantitative coursework
  • Dynamical Systems6.00 / 6.0
  • Numerical Analysis6.00 / 6.0
  • Analysis III6.00 / 6.0
  • Probability and Statistics5.75 / 6.0
  • Programming for Engineers5.75 / 6.0
  • Electrical Engineering Science & Technology5.75 / 6.0
  • Analysis IV5.50 / 6.0

EPFL grading scale: 6.0 is the highest possible grade; 4.0 is the passing grade.

Experience

  1. EPFL

    Sep 2024 – Jul 2025

    Teaching Assistant — Physics, Thermodynamics & Computation

    Teaching

    Supported a cohort of 500+ students across four course assignments: Physics: Mechanics (Prof. P. Müllhaupt), Physics: Thermodynamics (Prof. S. Bréchet and Prof. J. Genoud), and Information, Computation, Communication (Prof. O. Lévêque). Led exercise sessions, graded midterms, and gave feedback.

  2. EPFL Rocket Team

    Sep 2024 – Jul 2026

    Ground Station Subsystem Engineer — Firehorn

    Engineering

    Mechanical design, prototyping, and testing of ground support components for competition-level rocketry; CAD, 3D printing, CNC machining, and cross-subsystem integration.

  3. EPFL Coaching

    Sep 2024 – Jul 2025

    First-Year Student Coach

    Leadership

    Mentored first-year students through their integration at EPFL, sharing study methods and strategies for the foundation year.

  4. The Academy

    Jan 2021 – Jul 2023

    Founder & Director

    Entrepreneurship

    Created and led an online academic support platform bringing together several thousand students, with revenue generated through advertising partnerships.

View full CV ↗

Capabilities

Technical breadth

Tools and methods I work with across robot learning, control, engineering, and software.

Methods

  • Reinforcement learning (PPO)
  • Imitation learning (BC, DAgger)
  • Control systems & optimal control
  • Probabilistic modeling
  • Numerical methods

Programming

  • Python
  • PyTorch
  • ROS 2
  • C
  • MATLAB

Evaluation & tooling

  • Stable-Baselines3 & Gymnasium
  • Docker, unit tests & CI
  • Held-out test sets
  • Confidence intervals & ablations
  • N8N & LLM workflows

Engineering

  • SolidWorks
  • Fusion 360
  • CATIA
  • Abaqus
  • 3D printing & CNC machining

Languages|French (native) · English (C1) · Spanish (B1)

Status

Currently

First semester of the M.Sc. Robotics, Systems and Control at ETH Zurich, with coursework in probabilistic AI, vision for mobile robots, and optimal control. Graduating in 2028.

Looking for internships in robot learning, reinforcement learning, and computer vision from September 2027.

Contact

Let's build robots that learn and hold up in the real world.

Open to conversations and opportunities in robot learning, reinforcement learning, computer vision, and control.

Zurich, Switzerland